Alp Sahin
I am Alp, a PhD student in the Mechanical Engineering & Mechanics Department at Lehigh University, working at the Autonomous and Intelligent Robotics Laboratory (AIRLab) with Professor Subhrajit Bhattacharya. Before I joined Lehigh, I was a Master’s student in the Robotics Engineering Department at Worcester Polytechnic Institute (WPI). While at WPI, I worked at the Manipulation & Environmental Robotics (MER Lab) with Professor Berk Calli on search-based planning algorithms for in-hand manipulation.
My current research interests lie at the intersection of search- and optimization-based methods for combinatorial problems in motion planning. I develop algorithms addressing problems in multi-robot and tethered robot systems, as well as robotic manipulation.
Research Highlights
Multi-Path Planning using Neighborhood-Augmented Graphs
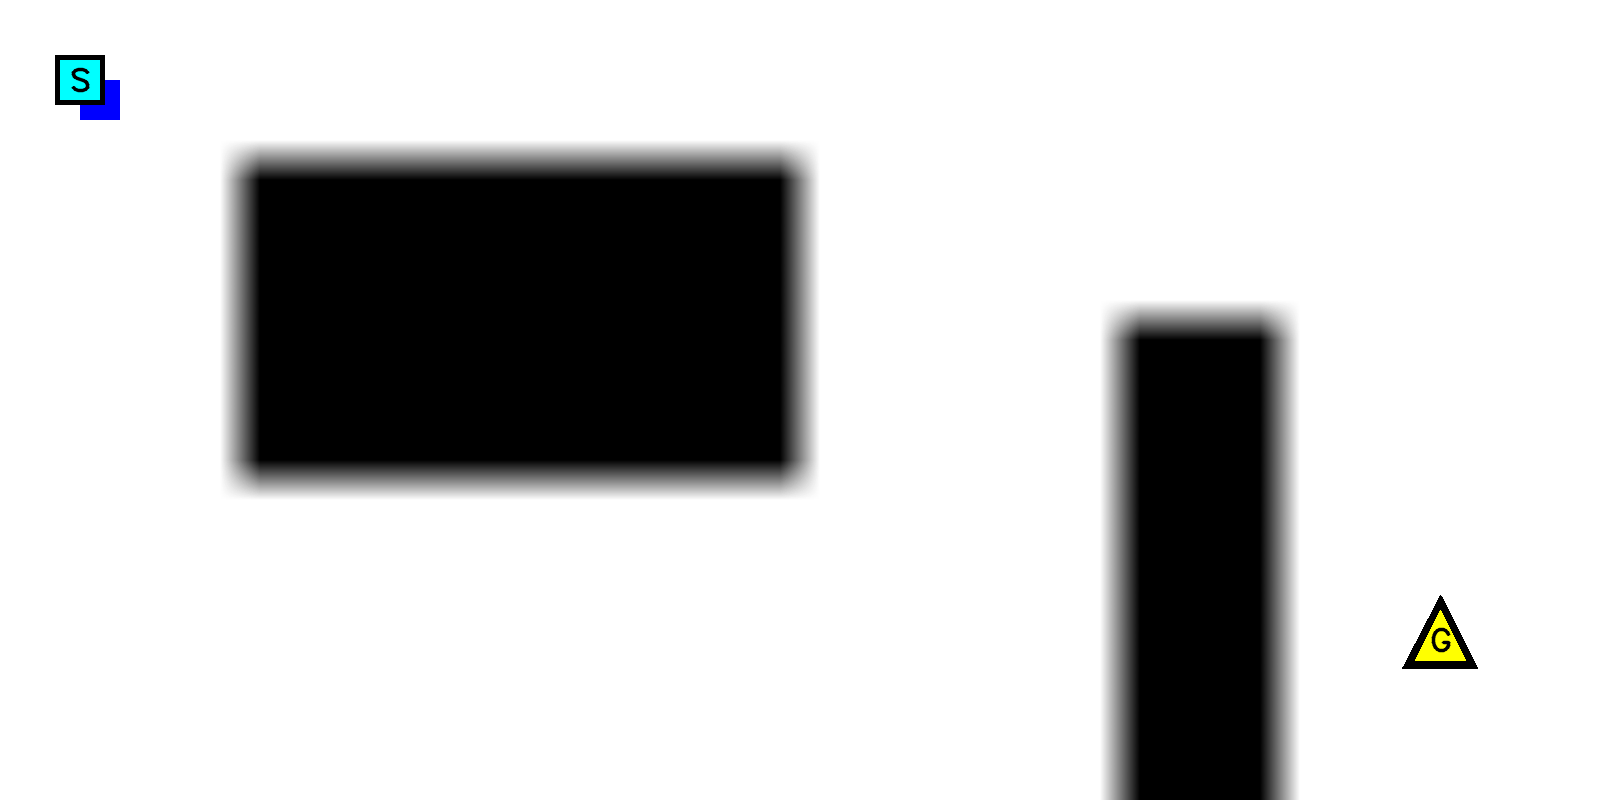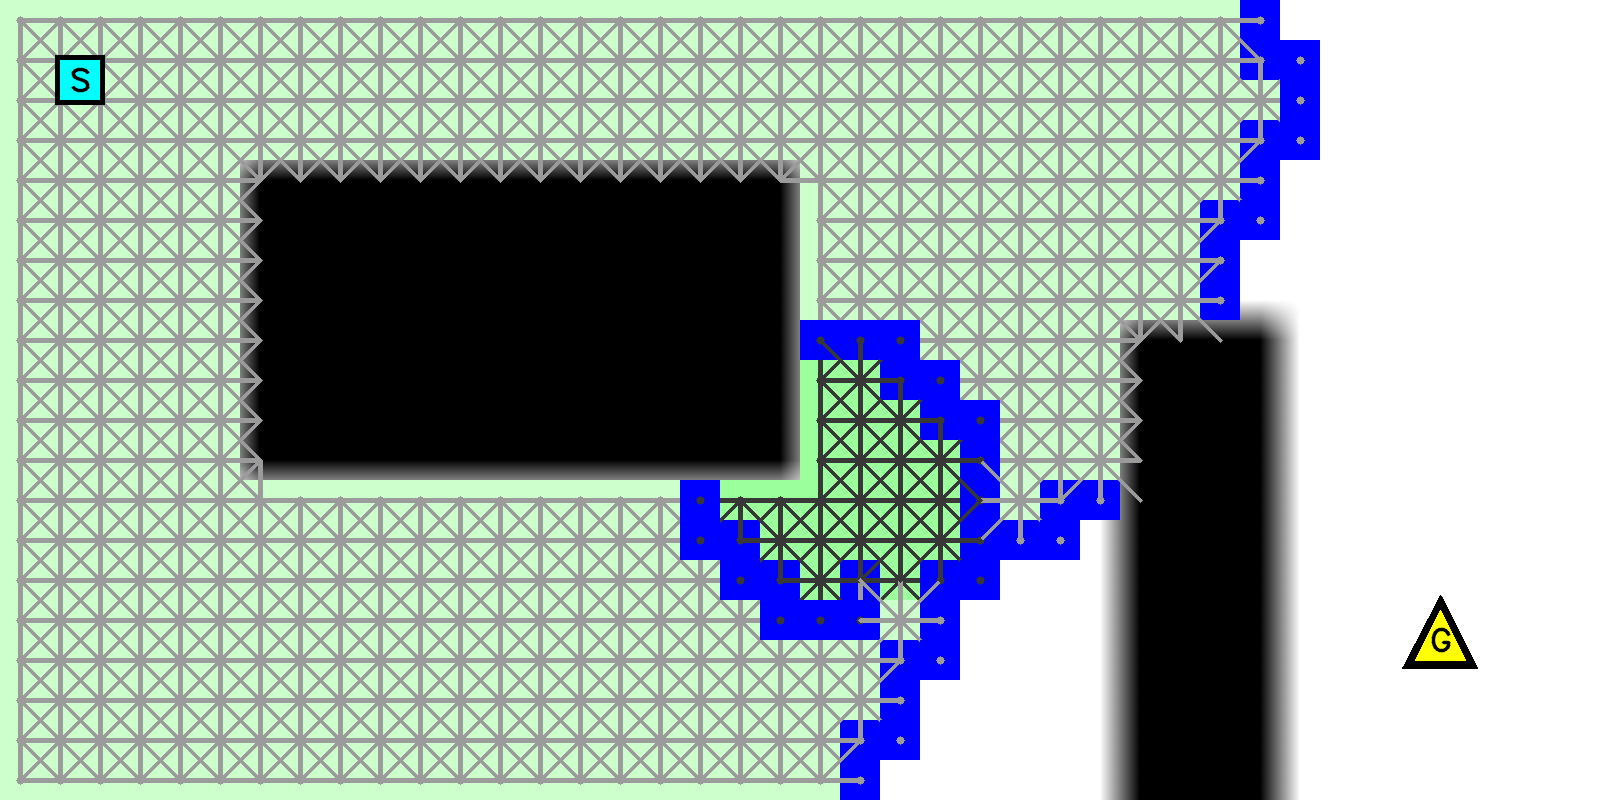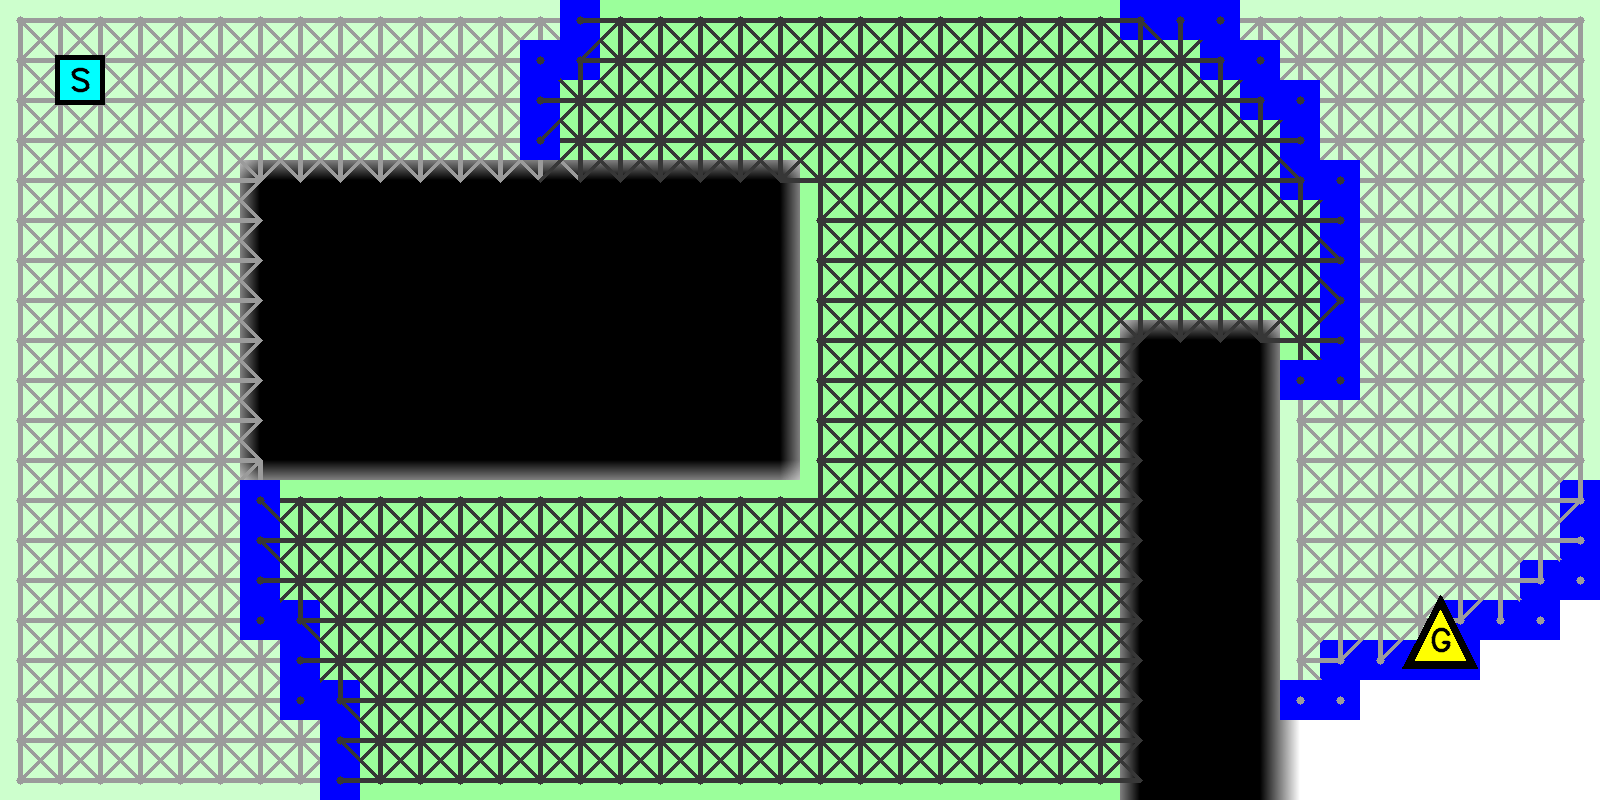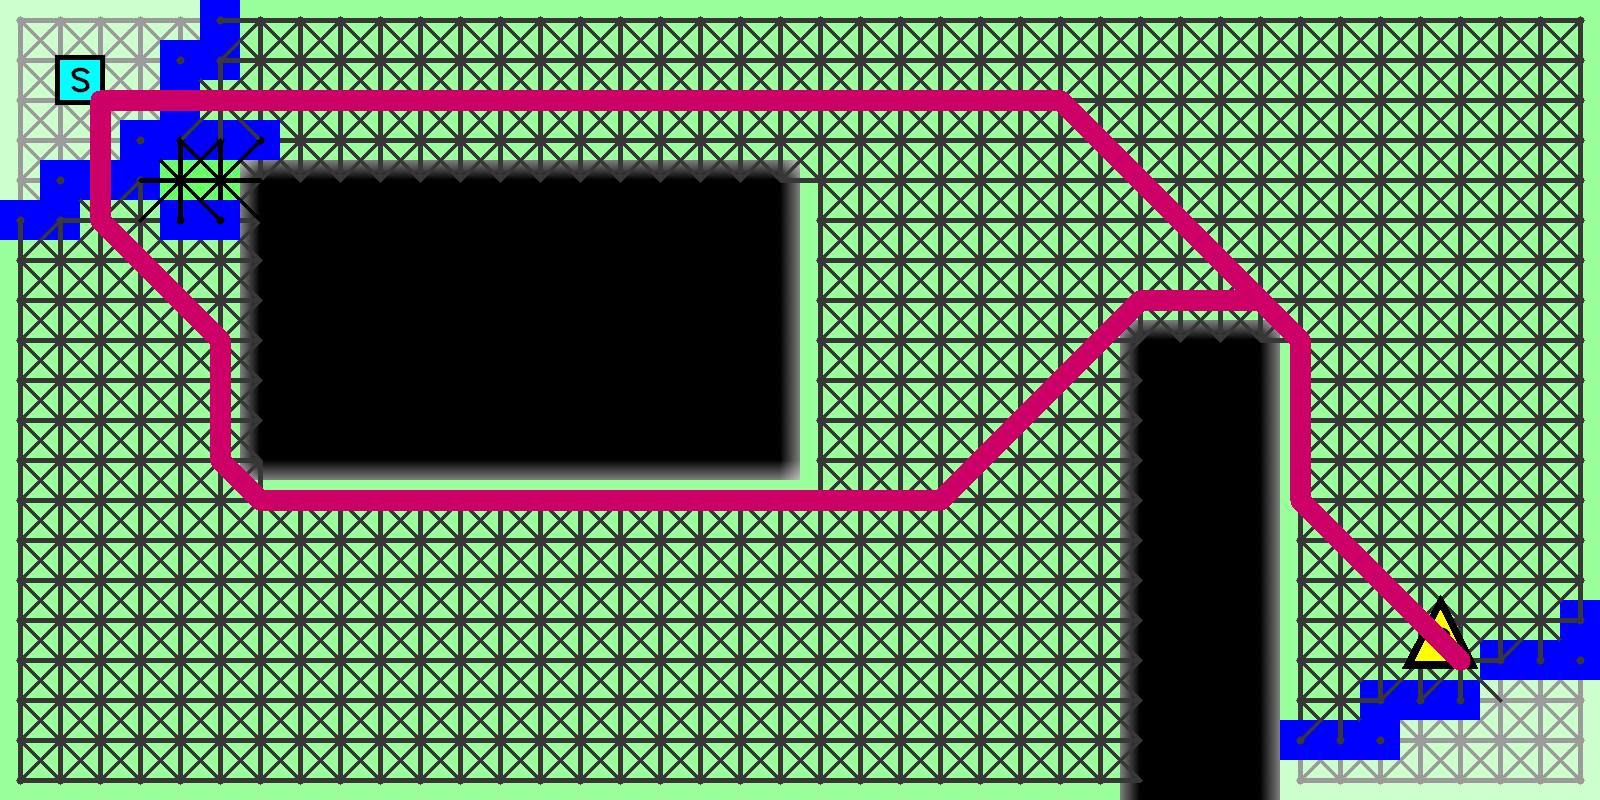
Robotics problems involving multi-robot teams and tethered robots require computation of multiple locally optimal paths in a configuration space. In this work, we utilize the notion of path neighborhoods to develop a search-based algorithm that plans for distinct paths. As opposed to the existing topological path planners, our algorithm can capture distinct paths even when they belong to the same homotopy class.
[Paper] [Code]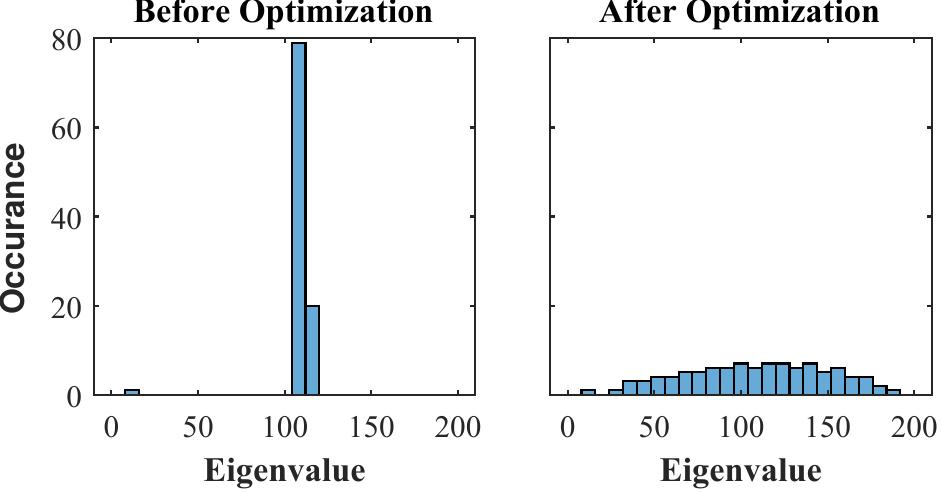
Optimization of Network Weights against Adversarial Resonance Attacks
An adversarial agent capable of injecting periodic signals into a network can perform "resonance attacks", aiming to drive the amplitude beyond the failure limits of the network. In this work, we explore two ways to mitigate such attacks: (1) adjusting the weights of the network edges, (2) attaching an auxiliary network that absorbs the excess energy. Assuming an adversary that stochastically chooses the attack frequency based on the network properties, our optimization framework minimizes the expected steady-state amplitude.
[Paper]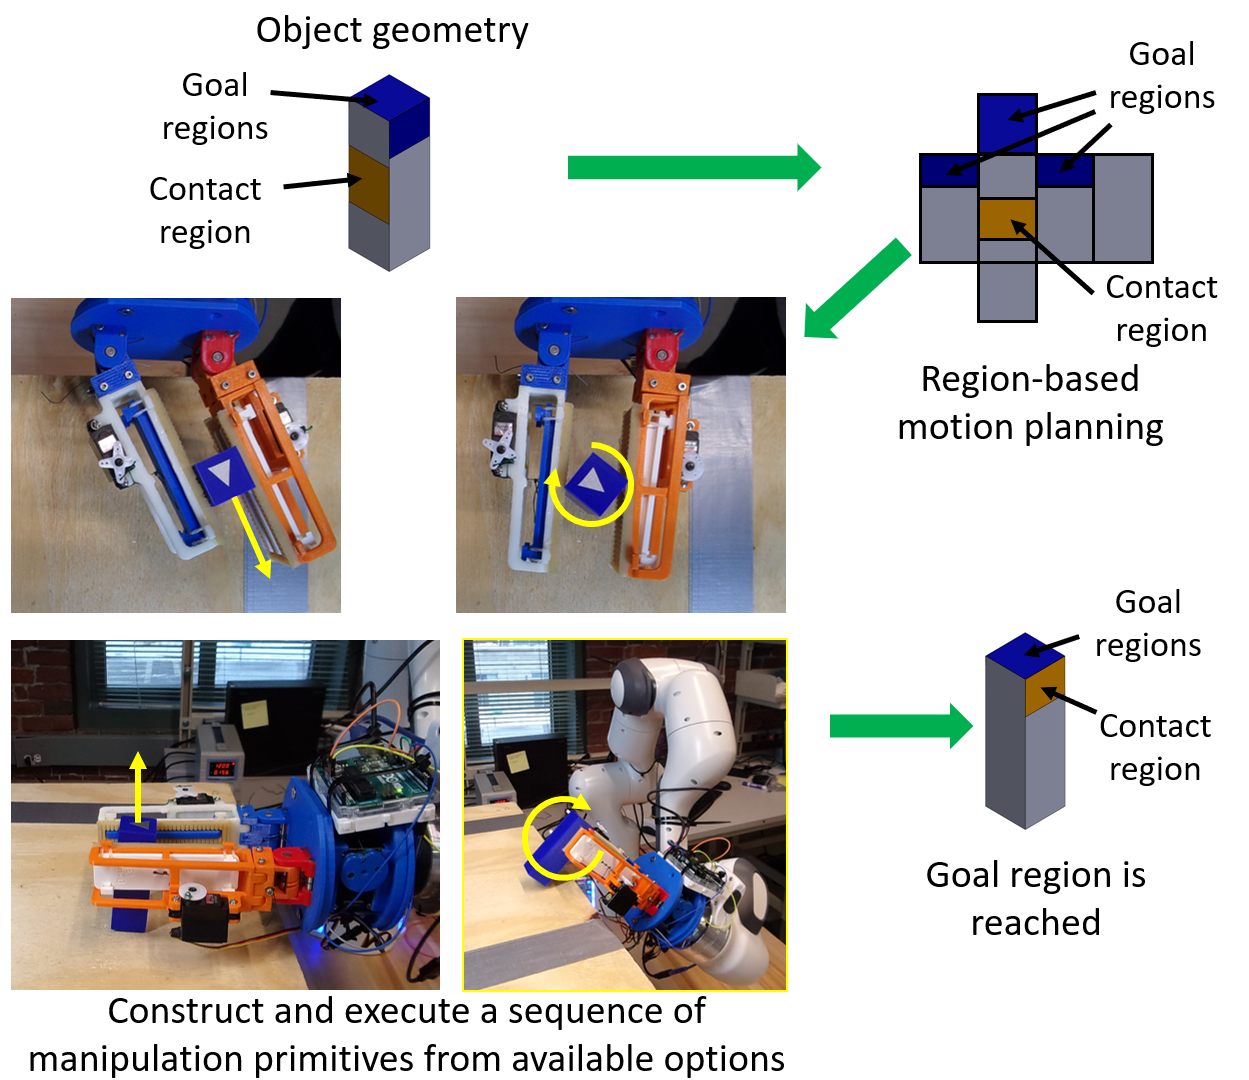
Contact Region Planning for In-Hand Manipulation
In-hand manipulation capabilities allow robots to operate with tools in confined spaces and with minimum energy consumption. This work features a real-robot setup consisting of a manipulator arm and a variable-friction gripper, that can perform key manipulation primitives such as controlled sliding, rotation, prehensile pushing, and pivoting. We develop a search-based algorithm that plans for a sequence of primitives to manipulate objects into target grasp configurations within hand.
[Paper] [Code (Simulation)] [Code (Planner)]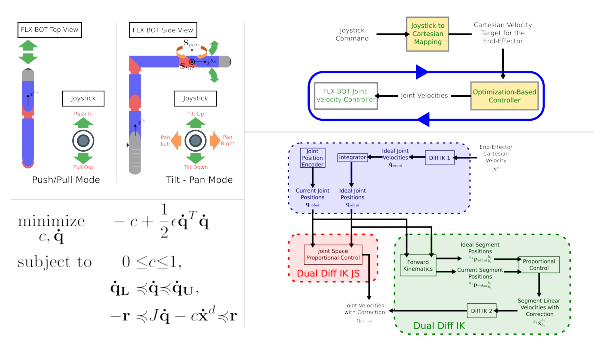
Optimization-based Control of a Snake-like Robot
In this work, we develop an intuitive translation of user intent (joystick inputs) into Cartesian velocity targets for the end-effector of a snake-like inspection robot. Observing that the inspection tasks require the robot to frequently operate around its singularities, we present an optimization-based controller to recover from singular configurations, while complying with user inputs.
[Paper]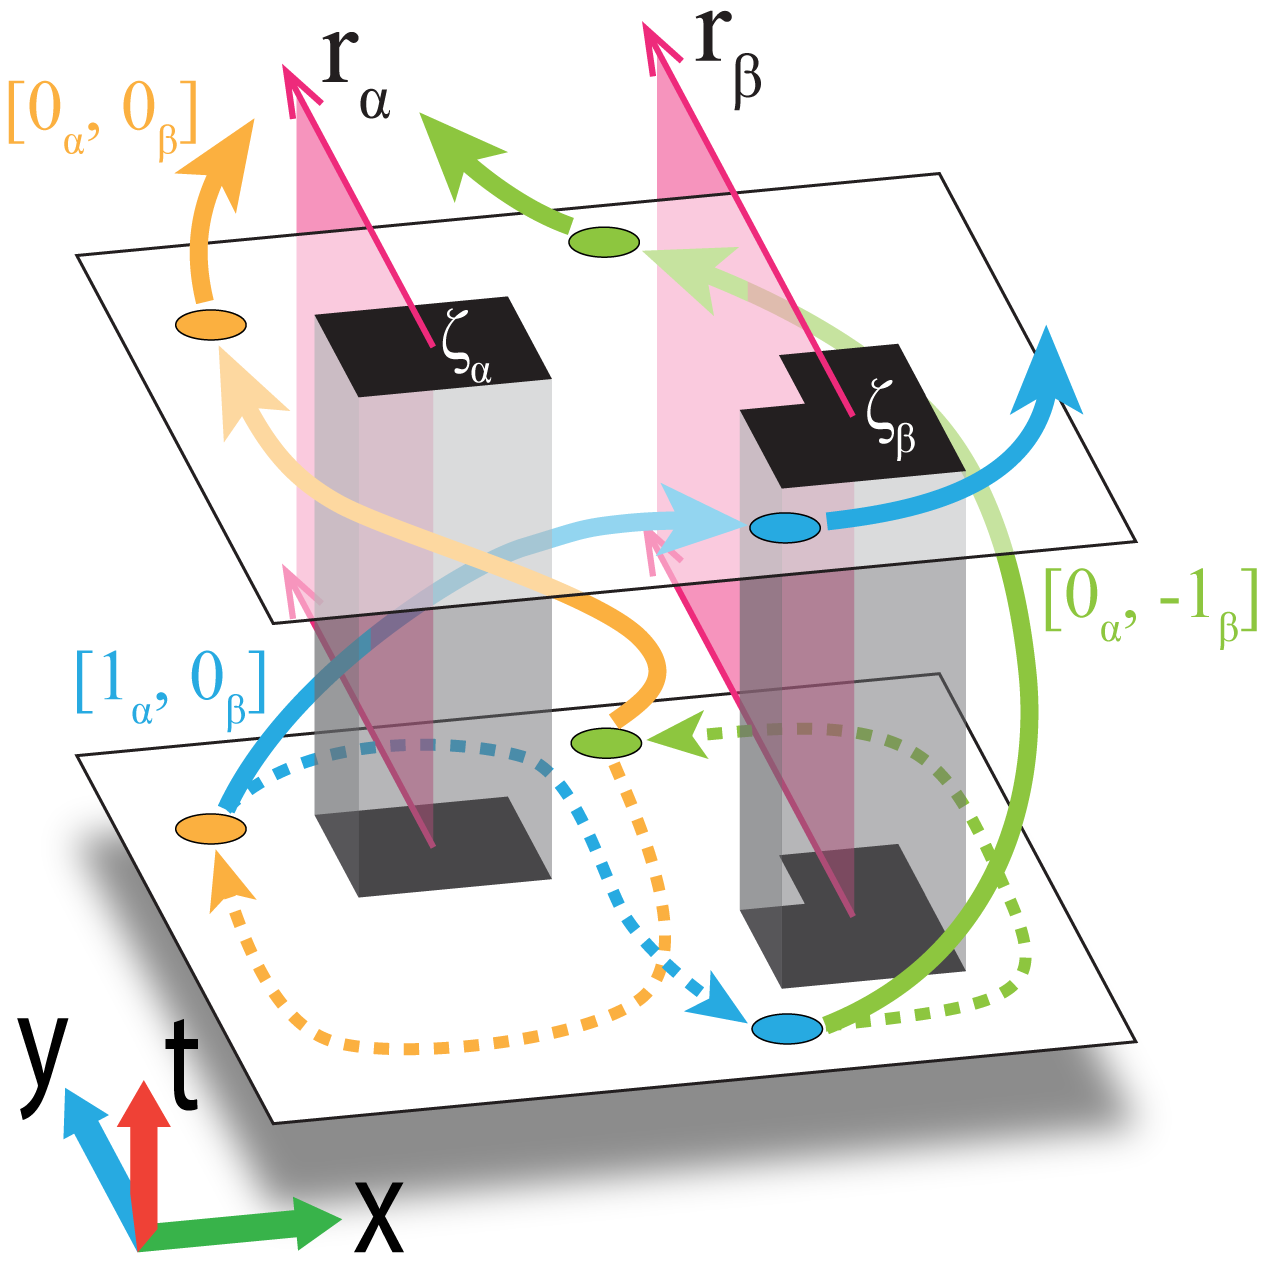
Coordination-free Multi-Robot Planning for Congestion Reduction
Many multi-agent systems operate under communication restrictions preventing high-level coordination. One example is autonomous vehicles that do not share navigation data due privacy concerns. In this work, we develop a decentralized path planning algorithm that (1) computes multiple routes and estimates the traffic density along each, (2) stochastically assigns the vehicle to a route to minimize the risk of congestion.
[Paper]